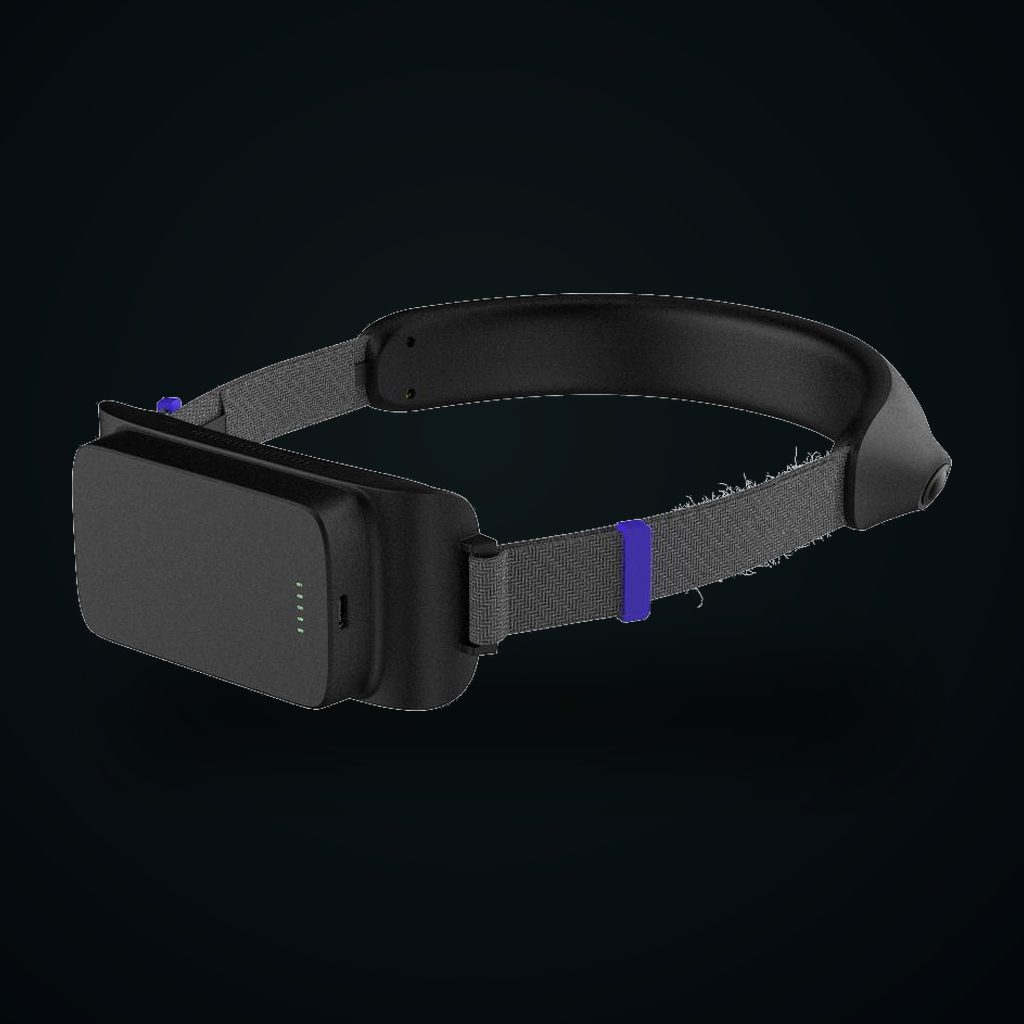
Wego4
Four synchronised global-shutter cameras cover 270° horizontally and 155° vertically, so the work zone stays in frame when the wearer turns. 3 TOPS of on-device compute runs quality checks while you record — bad takes get caught on the rig, not three weeks later in the annotation queue.
5 in stock — ships now
- 4 × SC233HGS global-shutter cameras — 270° horizontal × 155° vertical, minimal blind zone
- Rockchip RV1126B with 3 TOPS and a quad-core Cortex-A53 — on-rig quality control and lightweight perception
- Synchronised capture across all four channels with a shared hardware clock
- ICM-42688 6-axis IMU at 200 / 500 Hz, hardware-timestamped against video
- Wearable or mounted on a mobile platform — same data format either way
First 5 units ship from stock; beyond that, built to order in 30–60 days · 2-year warranty · Pairs with VisionLibra Data Services
Technical specs
| Basic | |
|---|---|
| Role | Quad surround egocentric terminal — wide work-zone coverage and high-value operation capture |
| Form Factor | Head-worn surround terminal / mobile-platform mount |
| Capture Coverage | Four synchronised global-shutter cameras, low blind zone |
| Typical Use | Robot data collection, mobile platforms, multi-angle task recording, industrial and lab operations |
| Cameras | |
| Sensor | 4 × SC233HGS, global shutter |
| Resolution | 1920 × 1200 (2 MP) per camera |
| Field of View | 270° horizontal × 155° vertical, ultra-wide surround |
| Compute | |
| SoC | Rockchip RV1126B |
| NPU | 3 TOPS — on-device quality control and lightweight perception |
| CPU | Quad-core Arm Cortex-A53 |
| Motion & Sync | |
| IMU | ICM-42688, 6-axis |
| IMU Rate | 200 Hz / 500 Hz |
| Time Alignment | Hardware timestamps across all four cameras and the IMU |
| Power | |
| Main Battery | 5600 mAh, hot-swappable |
| Backup | 500 mAh UPS — bridges the swap |
| Connectivity & Storage | |
| Wireless | Wi-Fi 6 dual-band + BLE 5.4 |
| Storage | microSD (TF) card |
| Data Output | |
| Video | MP4 / H.265 |
| Metadata | Per-image timestamps, IMU timestamps, audio, calibration parameters |
| Software | Linux, open data interface, offline trajectory-solving tools |
Built for
Manipulation Data
Hands stay in frame through the whole reach-grasp-place cycle.
Mobile Platforms
Bolt it to an AMR and capture the same surround view the robot sees.
On-Rig QC
3 TOPS flags blur, occlusion and dropped frames before the take leaves the site.
Lab & Industrial
Multi-angle procedure capture where a single forward camera loses the detail.
Surround capture with quality control at the edge
Capturing a dataset rather than building one device? Our data services team runs collection, annotation and evaluation on top of this hardware.